|
Chengyang Li (李承阳) I am a first-year jointly supervised Ph.D. student at SJTU and EIT, where I am advised by Prof. Wentao Zhu. Previously, I interned at Galbot, under the guidance of Prof. Li Yi. I received my bachelor's degree from ShanghaiTech University, where I was fortunate to work closely with Prof. Lan Xu, Prof. Jiayuan Gu, and Prof. Jingyi Yu. My research interests lie in Physical RSI. Email / CV / Google Scholar / Github |

|
Research |
* Equal contribution. † Corresponding author.
|
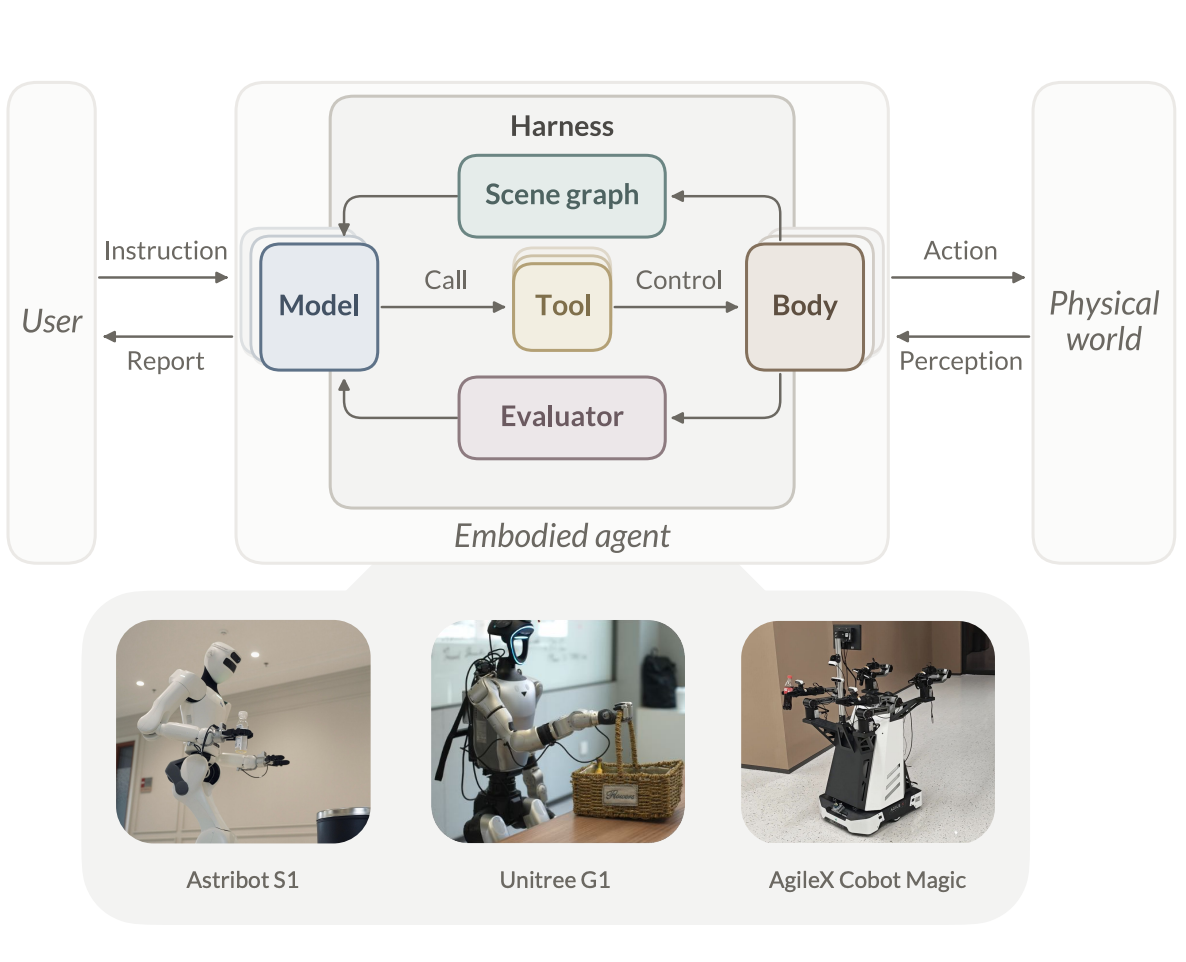
Thea: Towards the Harness of Embodied Agents
Qi Wang*, Tianyi Wang*, Chengyang Li*, Shikun Ban, Yurun Chen, Yizhong Ge, Jason Qin, Chengtai Li†, Wentao Zhu† Technical Report, 2026 Paper/ Code/ Project/ Video We present Thea, a harness that adapts the core components of coding agents to the physical world, where an agentic loop orchestrates robot capabilities wrapped as callable tools. |
|
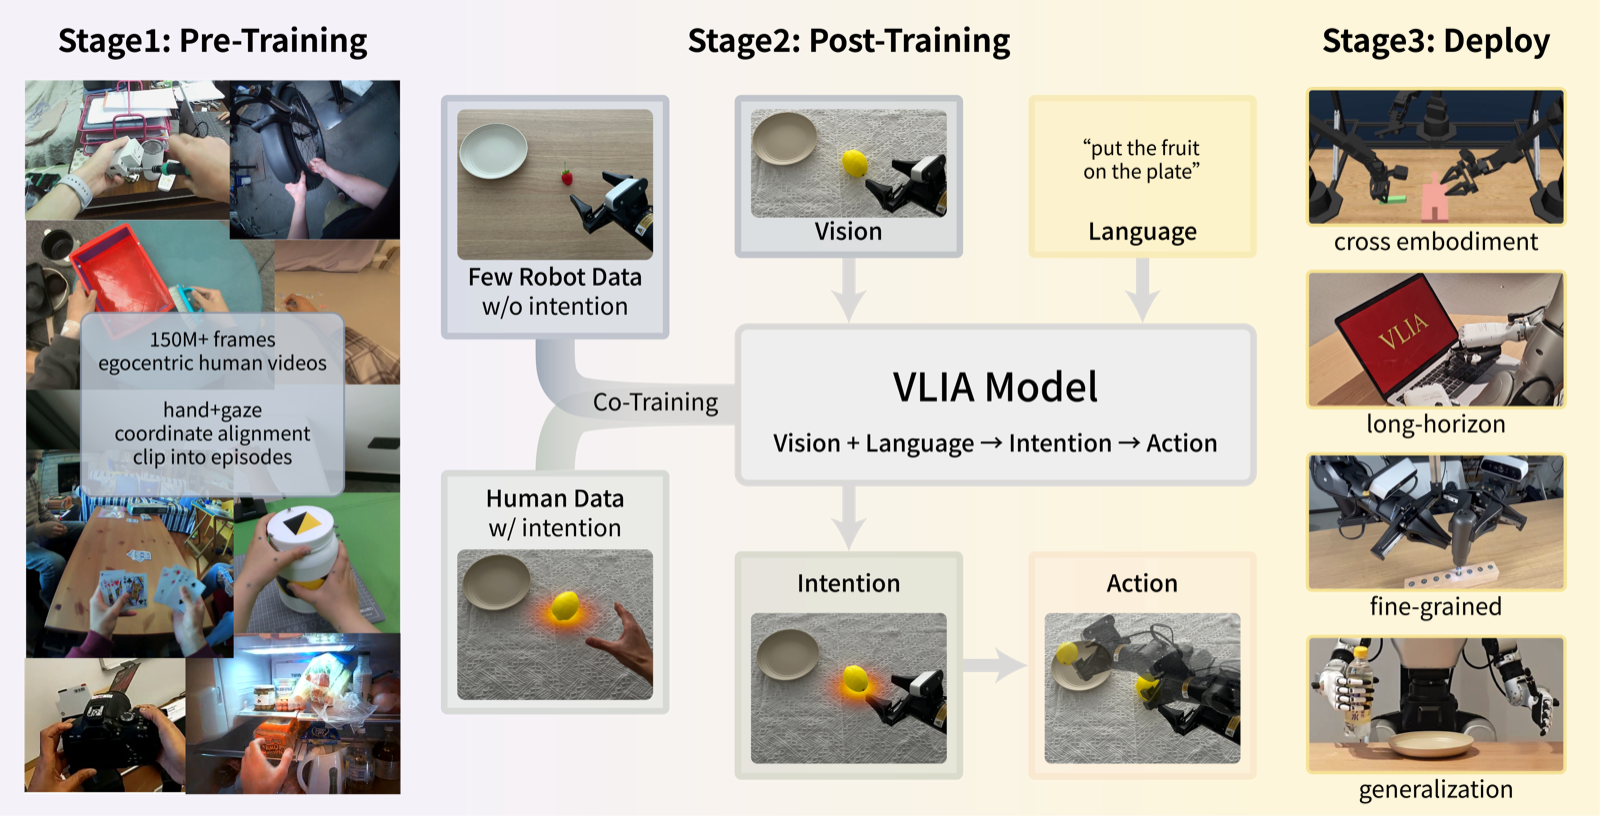
GazeVLA: Learning Human Intention for Robotic Manipulation
Chengyang Li*, Kaiyi Xiong*, Yuan Xu, Lei Qian, Yizhou Wang, Wentao Zhu† CoRL 2026 ★ Spotlight Paper/ Code/ Project/ Video/ Data We propose a novel learning-from-human framework that explicitly models intention to capture the causal structure of manipulation behavior. |
|
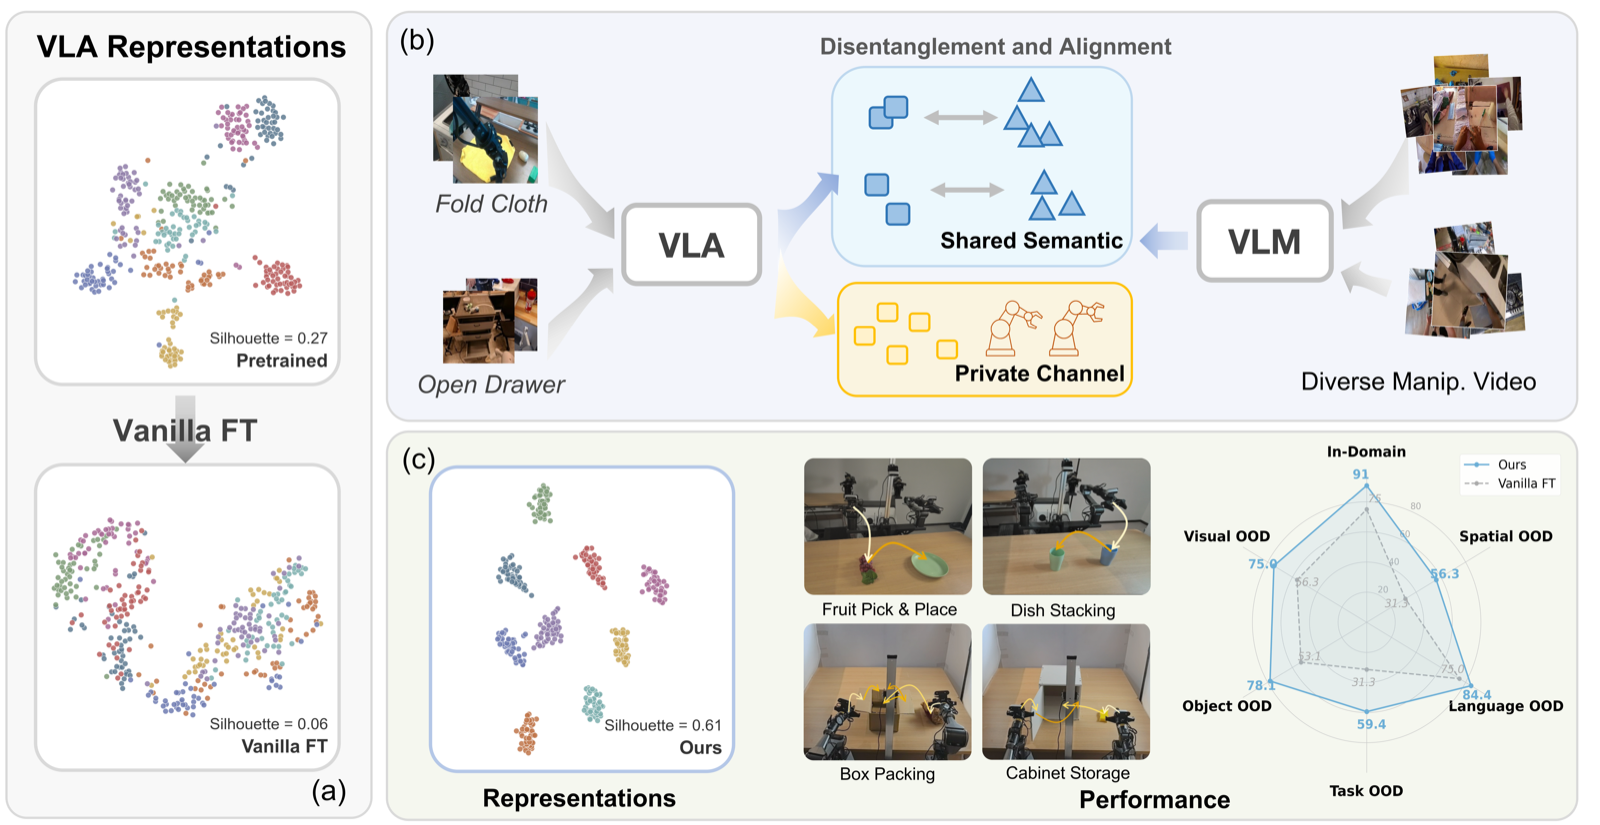
SemanticMN: Semantic Anchoring for Robotic Action Representations
Yuan Xu*, Youheng Shi*, Chengyang Li, Wentao Zhu, Yizhou Wang† CoRL 2026 ★ Spotlight Paper/ Code/ Project/ Video We anchor robotic action representations to a semantic manifold, improving task performance and generalization without changing the deployed model. |
|
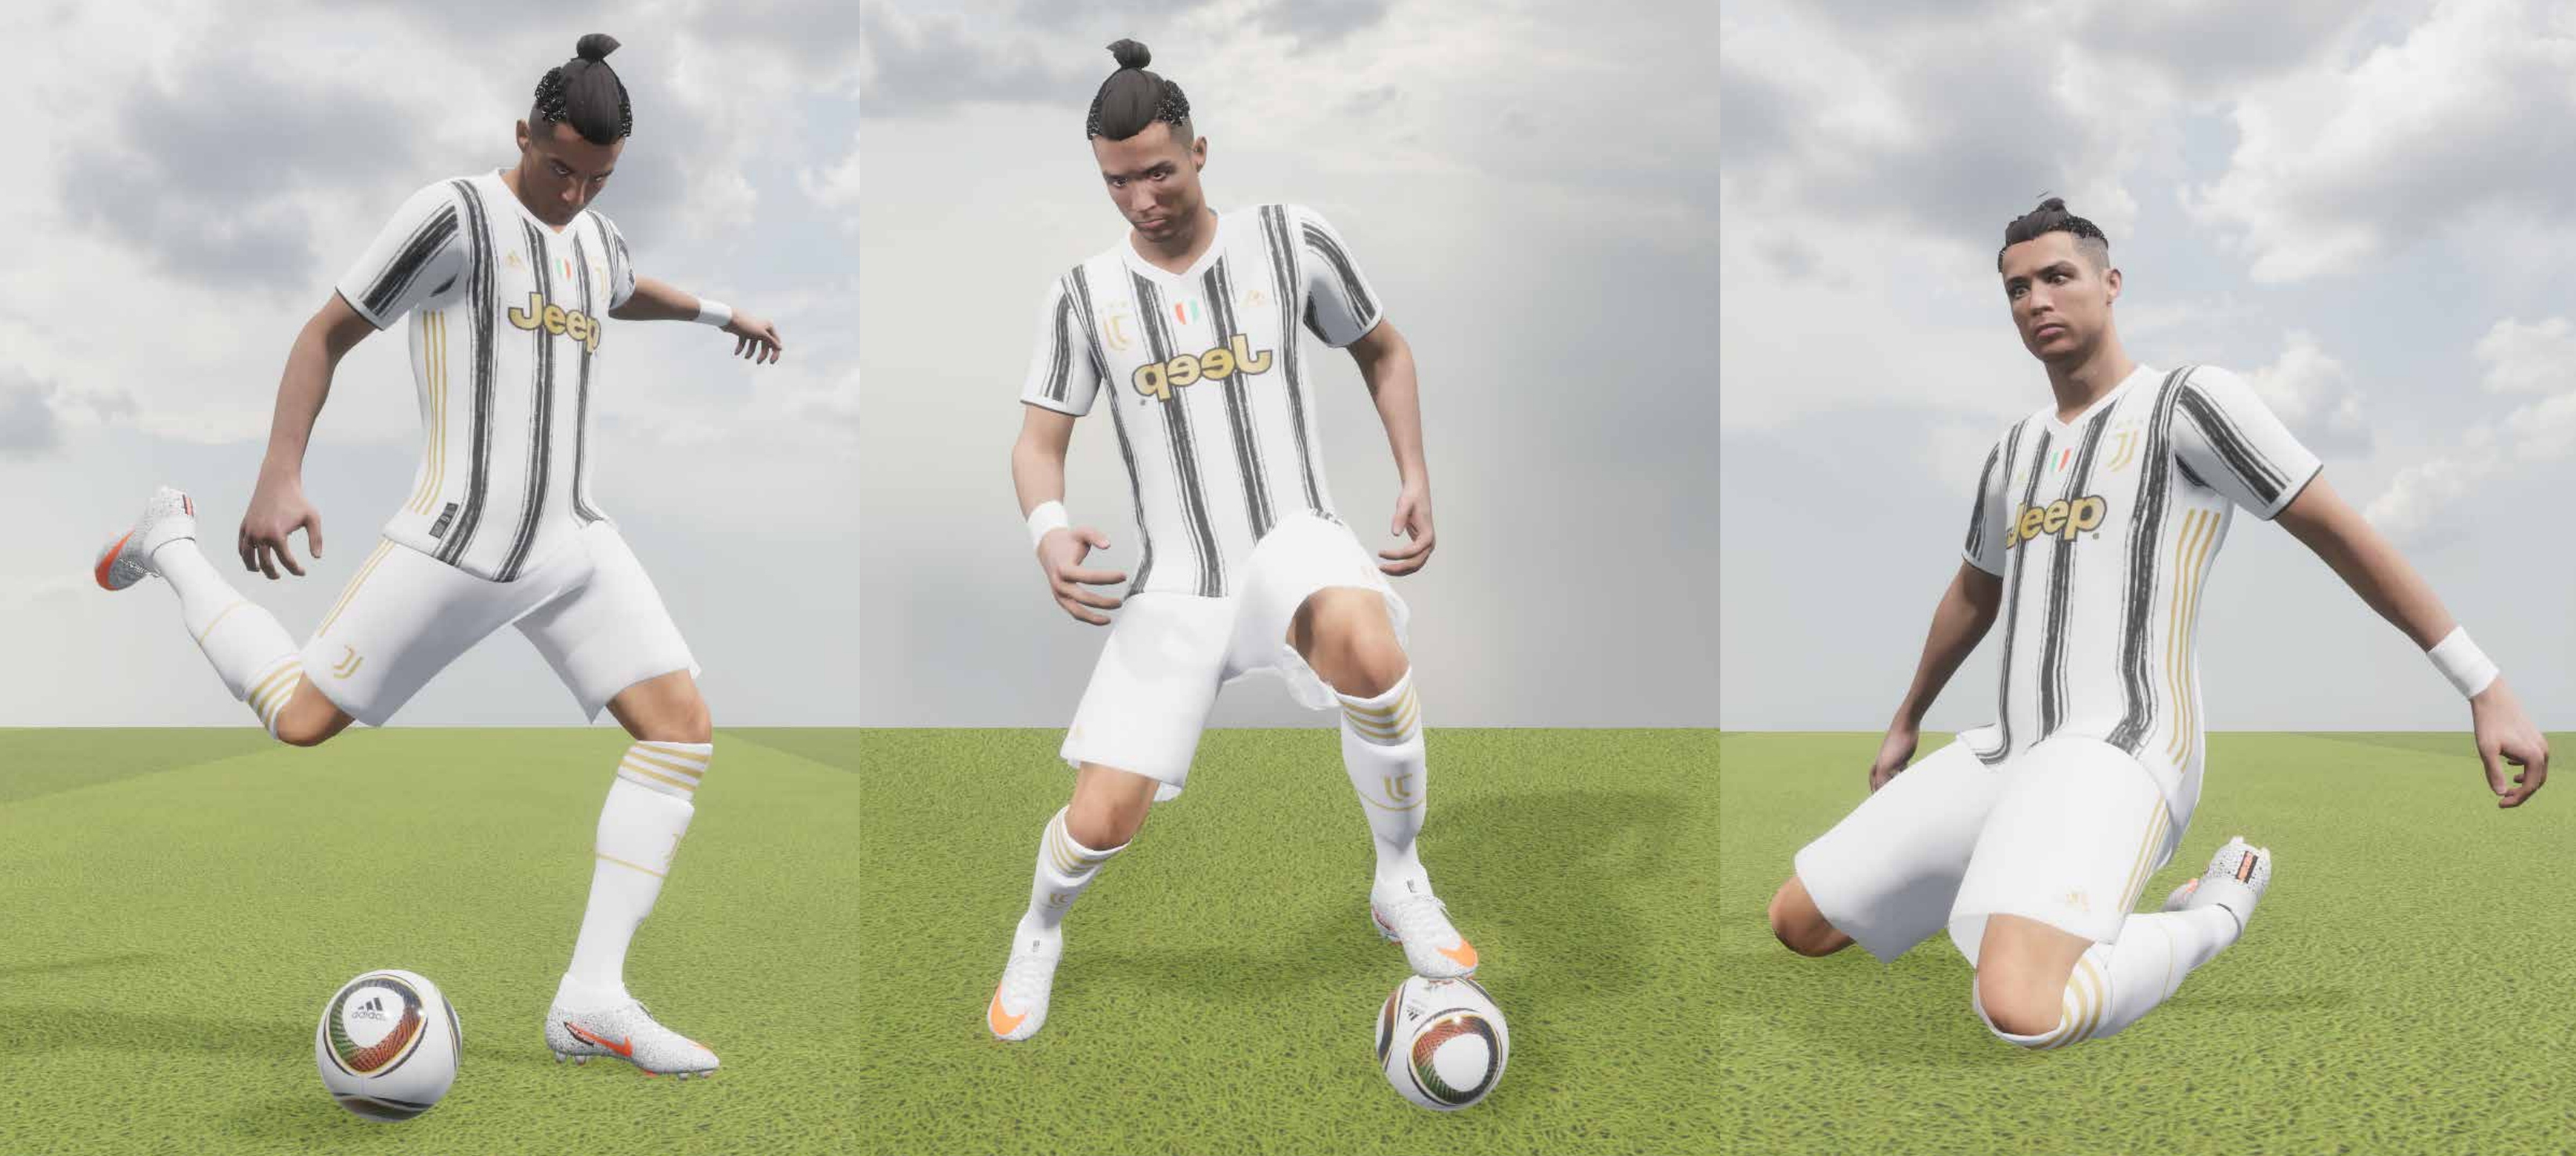
SMGDiff: Soccer Motion Generation using diffusion probabilistic models
Hongdi Yang*, Chengyang Li*, Zhenxuan Wu, Gaozheng Li, Jingya Wang, Jingyi Yu, Zhuo Su, Lan Xu† ICCV 2025 Paper/ Project/ Code/ Bibtex We introduce SMGDiff, a novel two-stage framework for generating real-time and user-controllable soccer motions. |
Experience |
|
MirroS
2026.09 - Present Research Intern |
|
Shanghai Jiao Tong University
2026.09 - Present Ph.D. Student Research Advisor: Prof. Wentao Zhu |
|
Eastern Institute of Technology, Ningbo
2026.09 - Present Jointly Supervised Ph.D. Student |
|
ShanghaiTech University
2022.09 - 2026.06 Undergraduate Student, GPA ranking 6/162 |
|
Galbot
2024.12 - 2025.06 Research Intern Research Advisor: Prof. Li Yi |
|
This homepage is designed based on Jon Barron's website. Last updated: 2026.09 |